| Myth | Reality |
|---|---|
| Once a cobot cell passes its initial risk assessment, the safety zones never need to be touched again. | Protective separation distances must be re-validated after firmware updates, sensor swaps, floor changes, or shifts in how fast operators typically walk near the cell. |
| Speed and separation monitoring (SSM) is a plug-and-play feature built into the cobot controller. | SSM is a system-level safety function that depends on external sensors, mounting geometry, lighting conditions, and a documented protective separation distance calculation. It is rarely a set-and-forget feature. |
| A single successful walk-through test proves a zone is safe. | Validation requires repeated trials from multiple approach angles and speeds, plus edge-case testing such as crouching, reaching over a guard, and fast lateral movement. |
| More sensor coverage always makes a cell safer. | Overlapping sensor fields without proper zone tuning create nuisance stops, and operators who get tired of nuisance stops eventually find ways to defeat the system. |
Why Speed and Separation Monitoring Fails on Real Production Floors
Speed and separation monitoring, usually shortened to SSM, is one of the two collaborative operating modes defined for industrial robots alongside power and force limiting. In theory it is straightforward: the robot slows down or stops as a person gets closer, using sensors to track the distance between a human and the moving robot. In practice, the gap between the theoretical safety case and the working cell on the floor is where most incidents, near-misses, and expensive downtime actually happen. Safety consultants and standards bodies have documented for years that the underlying protective separation distance calculation in ISO/TS 15066 accounts for human movement speed, robot stopping distance, sensor response time, and position uncertainty for both the human and the robot. Every one of those four inputs is a field-measured number, not a spec-sheet number, and that is exactly where implementations go wrong.
Our companion piece on human-machine collaboration safety standards covers the regulatory backdrop for cobot deployments in detail, including how ISO 10218-1/2 and ISO/TS 15066 relate to one another. This article assumes you already understand that framework and instead walks through what integrators and plant safety engineers actually do when they calibrate, install, and validate an SSM system on a real production line – the part of the job that standards documents describe in principle but rarely explain step by step.
Step 1: Measuring the Inputs Before You Touch a Sensor
Before any sensor goes on a mounting bracket, the commissioning team needs four measured values, not assumed ones:
- Robot stopping distance and stopping time, measured at the actual payload and speed the cell will run, not the fastest or slowest catalog value. Stopping distance changes meaningfully with payload mass and arm extension, so a single generic number from the robot manual is not sufficient for a specific application.
- Sensor response time, including the time for the detection device itself to register a person, plus the communication latency to the safety controller, plus the time for the controller to command a stop. Vision systems, safety-rated area scanners, and time-of-flight sensor arrays all have different latency profiles, and manufacturers rarely quote worst-case latency under real network load.
- Human approach speed, which standards bodies default to a conservative 1.6 meters per second unless a documented task analysis justifies a different value. Fast-walking maintenance staff or workers carrying loads can exceed this default in practice, which is why observational studies of the actual work cell matter more than the default number.
- Position measurement uncertainty, meaning how much error exists in where the sensor thinks the person and the robot actually are. This is rarely zero, and it directly inflates the protective separation distance when added correctly.
Skipping this measurement step and instead copying a protective separation distance from a similar cell elsewhere in the plant is the single most common shortcut that later shows up as a nuisance-stop problem or, worse, a near-miss.
| Input variable | Typical field method | Common error |
|---|---|---|
| Robot stopping distance | Measured with the safety-rated monitored stop function at production payload and speed | Using the no-load, minimum-speed value from the datasheet |
| Sensor response time | Measured end-to-end from detection event to commanded stop, including network hops | Using only the sensor’s internal processing time, ignoring controller and network latency |
| Human approach speed | Site observation of actual worker movement patterns near the cell | Assuming the standard default speed applies to every task, including fast maintenance walk-throughs |
| Position uncertainty | Bench-tested against a moving target at the sensor’s rated range and lighting conditions | Relying on the sensor vendor’s ideal-condition accuracy figure |
Step 2: Sensor Placement and Mounting Geometry
Once the four inputs above are measured, sensor placement becomes a geometry problem, not a guessing exercise. Area scanners, light curtains, 3D time-of-flight cameras, and on-robot ranging arrays each have blind spots created by mounting height, occlusion from fixed equipment, and the angle at which a person can approach the hazard zone. A few practices consistently separate cells that pass validation on the first attempt from cells that need repeated rework:
- Map every approach vector, not just the obvious aisle. Workers do not only approach from the main walkway; they reach in from adjacent workstations, lean over conveyor guarding, or step through gaps left for material flow. Each of these vectors needs its own detection coverage check.
- Mount sensors above the height of typical material carts and bins. A sensor mounted at torso height will be blinded the moment someone pushes a cart through the zone, creating an undetected approach path exactly when the floor is busiest.
- Account for mutual interference between overlapping sensors. Multiple time-of-flight or lidar-based devices aimed at overlapping fields can produce crosstalk that either creates false detections or, worse, masks real ones. Vendors typically publish interference mitigation settings that are skipped during rushed commissioning.
- Keep a documented sensor field-of-view diagram as a living document. When a nearby rack, cart parking spot, or fixture changes, the diagram needs to be checked against the new obstruction, not assumed to still be valid.
Protective zone layering around a cobot workcell
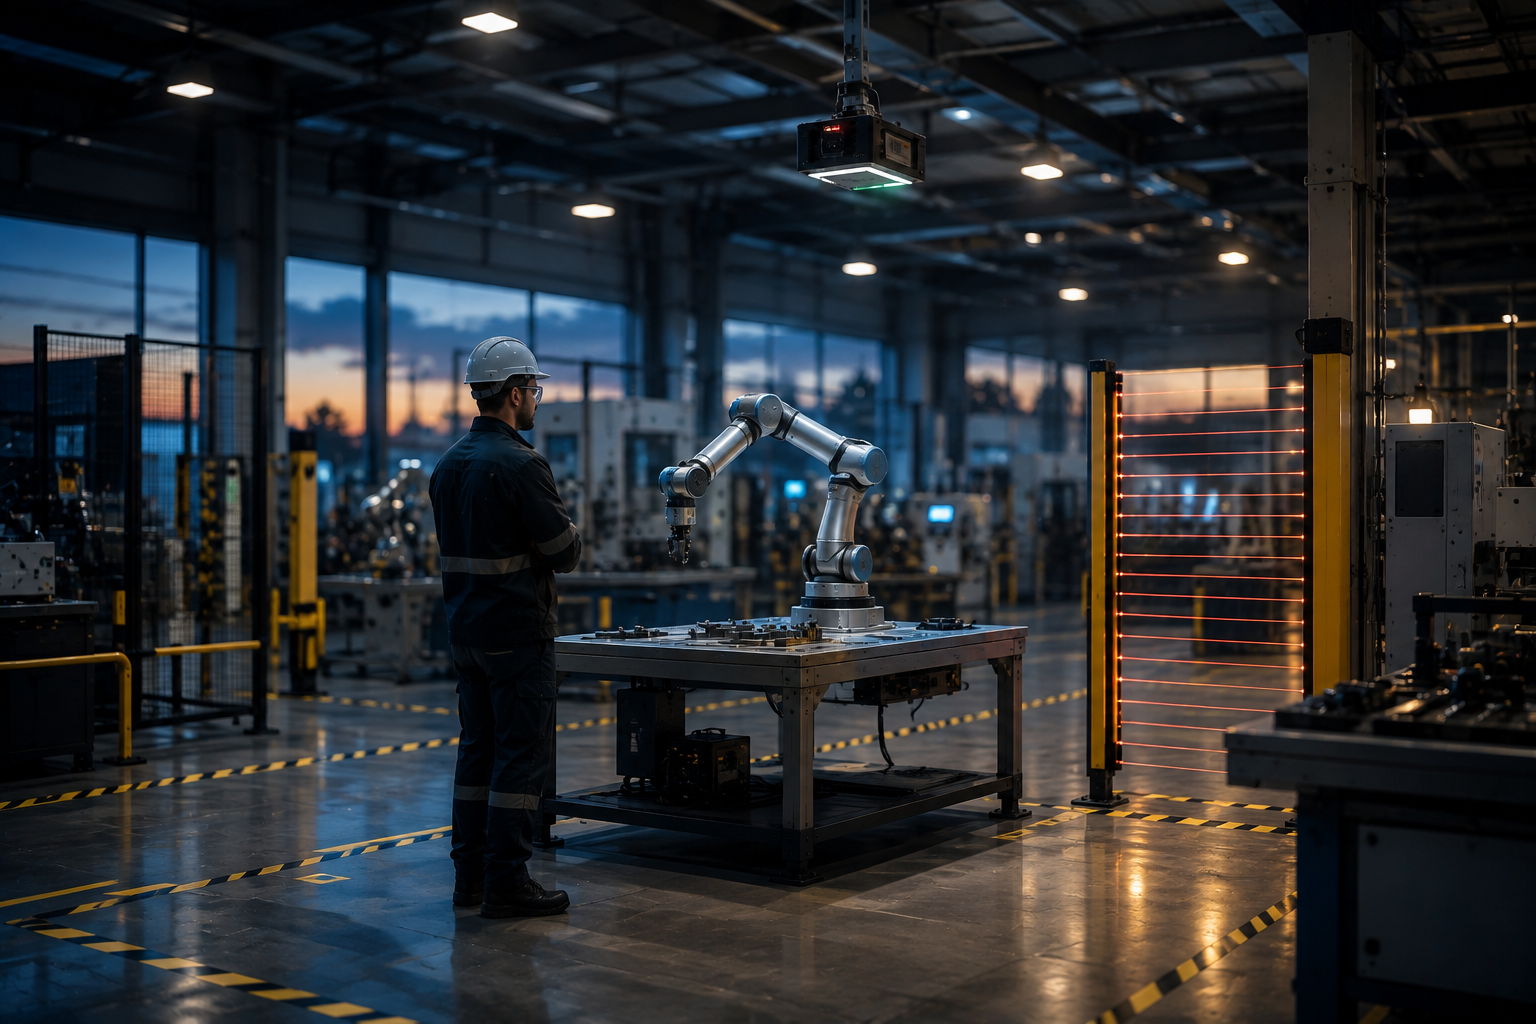
A typical field layout uses three concentric zones: an outer warning zone that triggers a speed reduction, a middle zone that triggers a slower monitored speed, and an inner zone that triggers a full protective stop. Each boundary is set back from the hazard by the calculated protective separation distance for that zone’s expected approach speed, with an added margin for sensor position uncertainty measured during commissioning.
Step 3: Defining Protective Zones That Match How the Cell Actually Runs
A protective zone drawn on a CAD layout and a protective zone that matches how operators actually move around a cell are frequently two different shapes. Effective zone definition starts with a walk of the physical floor with the process running, watching where people naturally stand, reach, and cut through. Zones are then built in layers: an outer boundary that only reduces speed, a middle boundary that drops the robot to a creep speed, and an inner boundary that forces a full protective stop. Each boundary distance is derived directly from the protective separation distance formula using the values measured in Step 1, not from a rule-of-thumb offset.
A frequent field mistake is setting a single static zone sized for the worst-case approach speed everywhere around the cell, even on sides where a wall or fixed guarding already makes fast approach physically impossible. This oversizes the safe zone, eats up valuable floor space, and increases nuisance stops without adding real protection. Dynamic, direction-aware zoning – where the protective distance varies by approach direction based on what is actually reachable from that side – is more work to commission but produces a cell that both keeps people safe and stays productive.
| Zone type | Robot response | Typical field-measured setback |
|---|---|---|
| Warning zone (outer) | Audible or visual warning, speed reduced to a documented safe operating speed | Set to cover worst-case approach speed plus full sensor and controller latency |
| Reduced-speed zone (middle) | Robot drops to a validated creep speed | Set to cover the remaining distance a person can close before a full stop completes |
| Protective stop zone (inner) | Full monitored stop of all hazardous motion | Set to the calculated protective separation distance plus measured position uncertainty margin |
Step 4: Validating the System After Installation
Validation is where most of the value of a correct implementation either gets confirmed or quietly falls apart. A defensible validation protocol includes, at minimum, the following elements, run and documented before the cell goes into production and again after any change:
- Multi-angle approach testing. Run trials from every mapped approach vector, not only the main aisle, using a calibrated moving target or a trained tester at multiple speeds up to the fastest realistic approach.
- Edge-case posture testing. Test crouching, reaching over a barrier, and moving an object into the zone ahead of a person’s body, since sensor detection profiles are frequently tuned around an upright walking adult and miss these cases.
- Nuisance-stop rate measurement over a full shift. Run the cell through a representative production shift and log every stop event, separating legitimate protective stops from false triggers caused by reflective surfaces, dust, vibration, or lighting changes.
- Reaction-time drift check. Periodically re-measure the sensor’s actual response time, since wear, contamination on sensor lenses, and controller software updates can quietly change latency without any alarm being raised.
- Documentation sign-off. Every validation run needs a dated record tied to the specific configuration tested, so that after any change the team can identify exactly what has to be re-tested rather than re-running the entire protocol from scratch every time.
Skipping the full-shift nuisance-stop measurement is especially common under schedule pressure, and it is also the step most likely to reveal that a zone is either unsafe in a way the short test never triggered, or so oversized that operators start propping open guards or standing outside a barrier that supervisors then quietly disable.
Common Field Failures and What Causes Them
Across a wide range of cobot deployments, the same handful of implementation failures recur:
- Sensor lens contamination in dusty or oily environments, which gradually degrades detection range without producing an obvious fault code, until a validation re-check or an actual near-miss reveals the drift.
- Reflective floor surfaces or newly installed guarding that create false detections for optical sensors, leading operators to disable a “flaky” system rather than reporting it, which quietly removes the safety function entirely.
- Firmware updates pushed to the robot controller or the safety sensor without a corresponding re-validation, sometimes changing default stopping behavior or sensor timing without a visible warning during commissioning.
- Layout drift, where racking, carts, or new fixtures get placed inside a mapped sensor field of view months after commissioning, creating a permanent blind spot nobody flags because it was never part of the original hazard walk.
- Under-measured human approach speed, particularly on lines where maintenance staff or forklift-adjacent workers move faster than the production-floor default used during the original risk assessment.
Common mistake
Treating the protective separation distance as a fixed number copied from a similar cell elsewhere in the plant, rather than recalculating it from measured stopping distance, sensor latency, and approach speed specific to the new installation. Two cells that look identical on paper can have meaningfully different real stopping distances once payload, mounting, and floor conditions are accounted for.
What worked
Running a documented full-shift validation with the process operating at real production pace, logging every stop event by cause, and reviewing the log with both safety engineering and floor operators before sign-off. This surfaced a blind spot created by a parts cart parking spot that the original CAD-based hazard analysis had missed entirely, and let the team fix sensor placement before the cell went live rather than after an incident.
Frequently Overlooked Details in SSM Implementation
- Muting and bypass loggingAny temporary bypass of a protective function during maintenance needs a timestamped log entry and an automatic reversion, or bypasses quietly become permanent.
- Lighting condition varianceVision-based sensors validated under daytime lighting can behave differently on a night shift or under different overhead lighting, so validation should include both lighting conditions actually used.
- Cable and connector wearSafety-rated sensor cabling routed through moving structures degrades faster than fixed cabling and should be on a defined inspection interval, not left to fail visibly first.
- Cross-zone tool changesSwapping an end effector changes the robot’s reach and mass distribution, which changes stopping distance, yet tool changes are frequently treated as a purely mechanical event with no safety re-check.
- Operator training refreshWorkers who get used to a system rarely triggering stops can develop complacent approach behavior, so periodic refresher walk-throughs matter as much as the initial training session.
Building a Repeatable Calibration and Validation Checklist
Plants that consistently pass audits and avoid repeat incidents tend to formalize the four steps above into a checklist that travels with every cobot cell, rather than treating commissioning as a one-time project task. A durable checklist includes the measured stopping distance and sensor latency values on file, a current sensor field-of-view diagram, a log of every validation run with pass or fail results by test case, and a defined trigger list of changes that require re-validation – firmware updates, tool changes, layout changes, and new personnel roles working near the cell. Building this checklist into the maintenance management system, rather than a standalone binder, makes it far more likely that a re-validation actually happens when a trigger event occurs months or years after initial commissioning.
Glossary
- Speed and separation monitoring (SSM)
- A collaborative operating mode where a robot’s speed is continuously adjusted, up to and including a full stop, based on the measured distance to a person in its workspace.
- Protective separation distance
- The minimum distance a safety system must maintain between a hazard and a person, calculated from stopping distance, sensor latency, approach speed, and position uncertainty.
- Power and force limiting (PFL)
- The other primary collaborative operating mode, where the robot itself is designed to limit contact force and power so that brief incidental contact does not cause injury, used instead of or alongside SSM.
- Monitored stop
- A safety function where the robot halts motion but remains powered, allowing a faster resume than a full category-0 or category-1 emergency stop.
- Nuisance stop
- A protective stop triggered by something other than a genuine hazard condition, such as sensor noise, reflective surfaces, or environmental interference.
- Position uncertainty
- The margin of error in a sensor’s measurement of where a person or robot actually is, which must be added into the protective separation distance calculation.
Key Takeaways
- Speed and separation monitoring is only as good as the measured inputs behind it: real stopping distance, real sensor latency, real approach speed, and real position uncertainty.
- Copying a protective separation distance from a similar cell elsewhere in the plant is a common shortcut that produces an unvalidated safety case.
- Sensor placement has to account for every realistic approach vector, not just the main walking aisle into a cell.
- Layered protective zones that vary by approach direction keep cells both safer and more productive than a single oversized static zone.
- Validation needs multi-angle, multi-posture testing across a full production shift, not a single successful walk-through.
- Nuisance stops that get ignored or worked around by frustrated operators quietly erode the safety function over time.
- Layout drift, tool changes, and firmware updates are the most common silent triggers for a protective zone becoming invalid without anyone noticing.
FAQs
What is the difference between speed and separation monitoring and power and force limiting?
Speed and separation monitoring keeps a robot away from people using sensors and distance calculations, slowing or stopping motion as someone approaches. Power and force limiting instead relies on the robot’s own design to cap contact force, allowing brief incidental contact without a full stop.
How often should a speed and separation monitoring system be re-validated?
Re-validation should happen after any firmware update, sensor replacement, tool change, or layout change near the cell, plus on a routine schedule, typically annually at minimum, to catch gradual sensor drift or wear that would not otherwise trigger an alarm.
Why do nuisance stops matter for safety, not just productivity?
Frequent false stops push operators toward workarounds such as disabling sensors or standing in blind spots to avoid triggering the system, which quietly removes the actual protective function even though the hardware is still installed.
What is the biggest cause of undetected blind spots in an installed cobot cell?
Layout drift is the most common cause: racking, parts carts, or new fixtures placed inside a sensor’s field of view months after commissioning, creating a permanent blind spot that was never part of the original hazard walk.
Does changing a robot’s end effector affect its safety zone?
Yes. A different tool changes reach, mass distribution, and stopping distance, all of which feed into the protective separation distance calculation, so tool changes should trigger a safety re-check rather than being treated as a purely mechanical swap.
What should a full validation test include beyond a basic walk-through?
A full validation test includes multiple approach angles and speeds, edge-case postures like crouching and reaching, a full-shift nuisance-stop log, and a reaction-time drift check, all documented and tied to the specific configuration being tested.
Can sensor lens contamination cause a safety failure without setting off any alarm?
Yes. Dust, oil film, or condensation on optical sensor lenses can gradually reduce detection range without producing a fault code, which is why periodic re-validation and physical sensor inspection matter as much as monitoring for error states.
Where can I read more about the underlying safety standards for cobots?
A broader overview of the ISO 10218 and ISO/TS 15066 standards framework, along with wider human-machine collaboration safety context, is available in our companion article on human-machine collaboration safety standards.
- ISA, “Take a Safe Approach to Collaborative Robots”
- PMC, “Implementing Speed and Separation Monitoring in Collaborative Robot Workcells”
- ScienceDirect, “Implementing speed and separation monitoring in collaborative robot workcells”
- Analog Devices EngineerZone, “Speed and Separation Monitoring for Robotic Applications”
- AMD Machines, “ISO 10218 and ISO/TS 15066: Robot Safety Guide”
- arXiv, “Evolution of Safety Requirements in Industrial Robotics: Comparative Analysis of ISO 10218-1/2 and Integration of ISO/TS 15066”
For related coverage in this series, see our guides to retrofitting legacy factories for robotics, robotic picking accuracy, multi-robot traffic management in dense warehouses, and future smart warehouse infrastructure.